POWERFUL & SMART

Our laboratory primarily develops automation systems for tractors with more than 100 horsepower and front- and rear-mounted implements used in large-scale farming in Tokachi, Hokkaido. We also develop precision field management systems using boom sprayers, agricultural drones, and small robotic rovers.

Lab Updates

◾Achievements of Graduate Students

2026/Sep. Hiroto ZUSHI, a second-year master's student, was selected for the Hokkaido IT Creator Discovery and Development Project (Shin-setsu Program).

◾Paper published

2026 Apr.
Our paper on spray height control has been published in the Journal of Robotics and Mechatronics.

◾Congratulations

2025 Mar.
Five students graduated and one completed their master's program. Congratulations! Thanks to our students, we were able to continue our research this year as well.

◾Graduate Student Wins Excellence Award

2025 Feb.
Yuka KOHARI, a first-year master’s student, received the Excellence Award at the 35th Yanmar Student Thesis and Essay Competition Presentation.

◾Paper published

2024 Sep.
Our paper on autonomous plowing operations has been published in the Journal of the Japanese Society of Agricultural Machinery and Food Engineers.

Research

Development of Automation Technologies for Crop Management Operations
Mobirise Website Builder
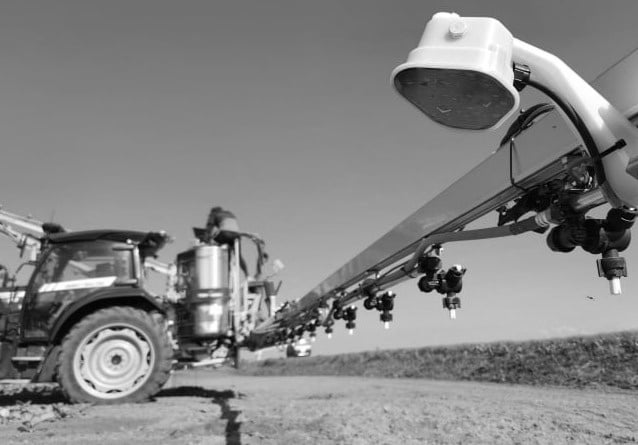
◾Autonomous Pesticide Spraying System

To automate pesticide spraying operations using large boom sprayers, several advanced technologies are required, including:
(1) automatic boom folding and unfolding at headlands,
(2) automatic boom-height control, and
(3) coordination with robotic tractors.
Our laboratory is conducting ongoing research and development to realize the practical implementation of unmanned pest control systems in society.
Mobirise Website Builder
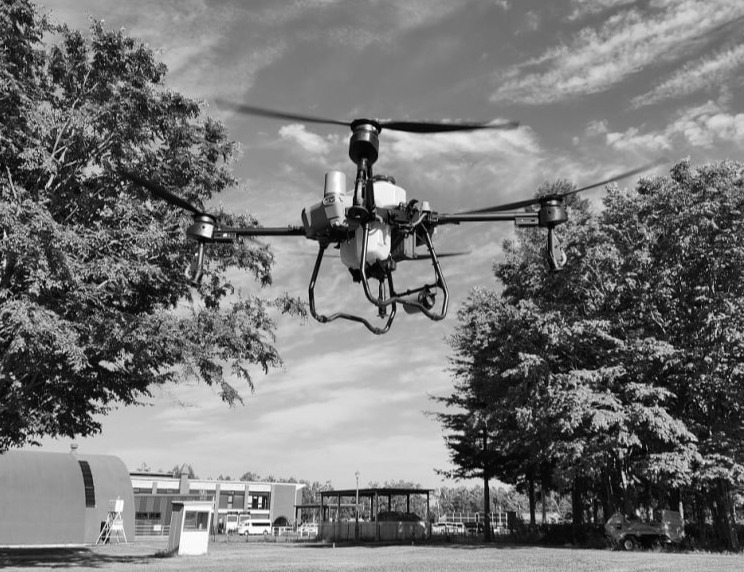
◾Visualization of Pesticide Drift

Visualization and Estimation of Pesticide Drift in Outdoor Applications
In outdoor pesticide applications, spray drift is influenced by turbulent wind conditions near the ground surface. Our laboratory is conducting research to estimate pesticide drift and visualize the distribution of spray coverage within the field.
Mobirise Website Builder
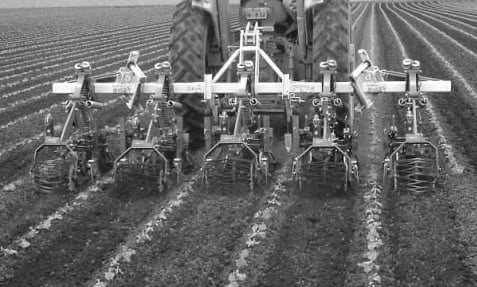
◾Automation of Inter-row Weeding

Cultivator-based weeding requires advanced driving skills due to the need for precise control. Even with auto-steering systems, operators are often forced to maintain awkward postures to monitor the implement from behind, in order to avoid damaging the crops. Our research aims to automate this task by using sensing technologies to recognize crop rows accurately.

‌

Best AI Website Maker